Bridge T-girders
8-AXIS · GMAW
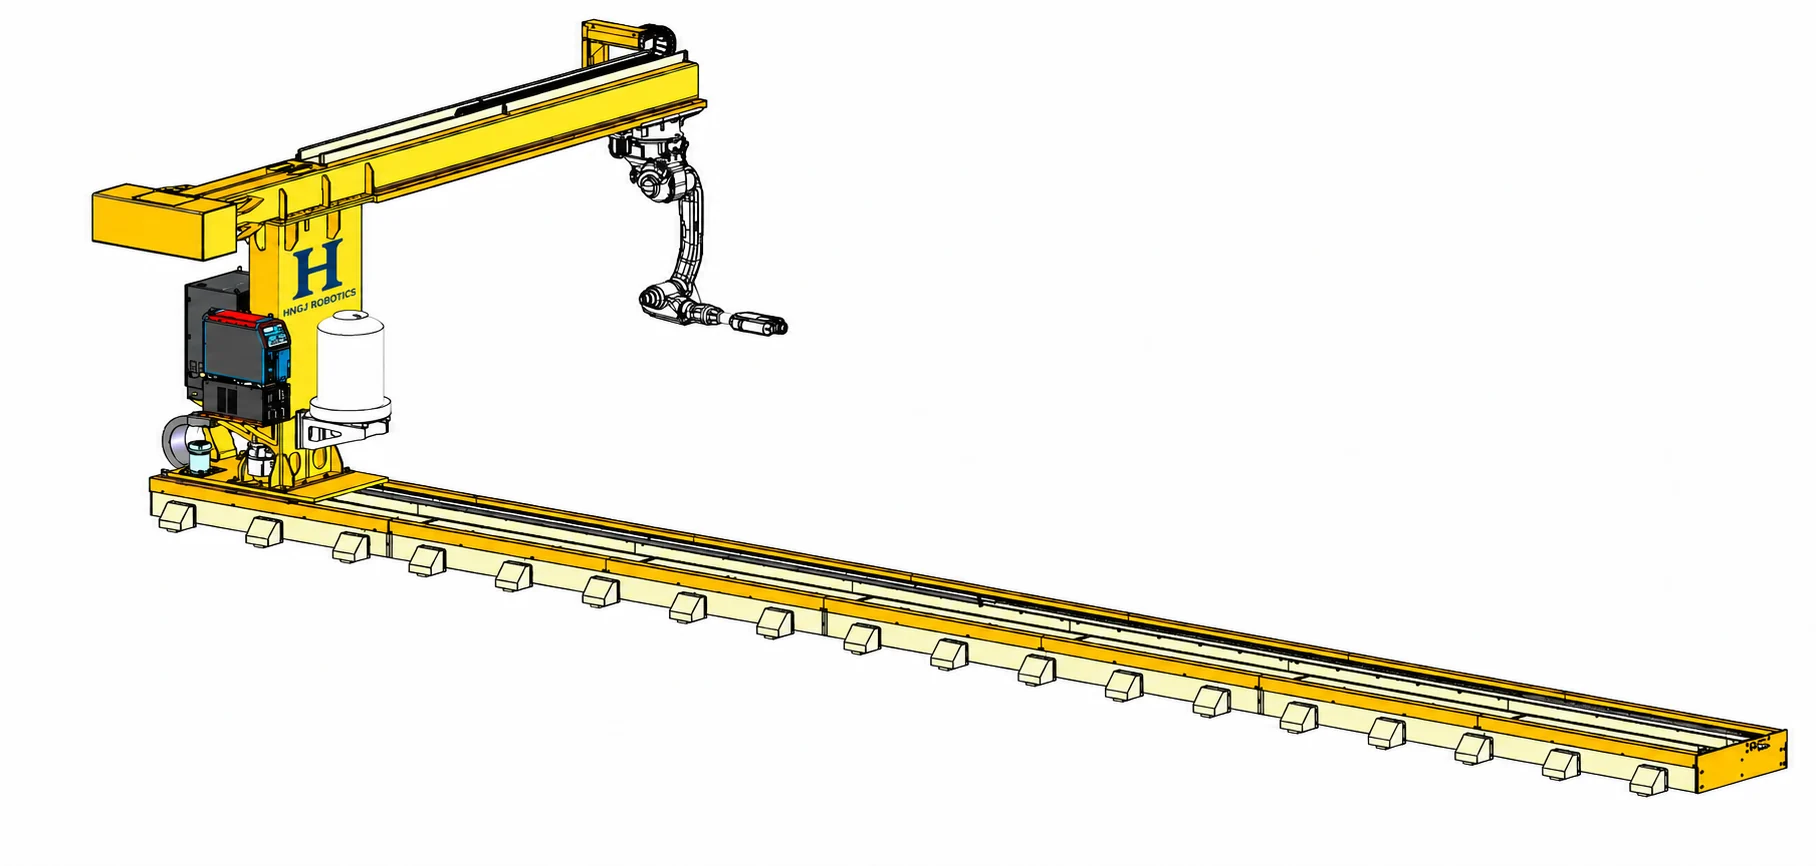
8-axis cantilever welding
A cantilever welding system with global scanning and close-range weld vision. Its operating envelope is configured around the workpiece and the available installation area.
Robotic welding6 + 2 motion axes
Enquire about this equipment01 / PRODUCT OVERVIEW
How this equipment works.
A cantilever workstation combines a suspended six-axis welding robot with two external motion axes. The moving cantilever extends the robot’s working area across the planned cell and leaves the workpiece arrangement to be designed around the fabrication task.
After the parts are tack-welded and positioned, global scanning identifies the assemblies and close-range vision refines the weld coordinates. The system combines these coordinates with welding-process data to generate the program. A water-cooled torch and automatic cleaning unit support the welding cycle.
Find the fit for your parts.
Bridge U-ribs
Bridge internal diaphragms
Circumferential seams of bridge internal diaphragms
Stiffener plates of bridge internal diaphragms
Construction machinery components
Ship hull sub-assemblies
Before choosing a configuration
Plate height, spacing and included angle affect scanning and torch access. Submit typical sections and fixture heights to verify the actual envelope and identify welds that need repositioning or a separate operation.
03 / PROCESS & CONFIGURATION
Designed for the task.
- Global scanning supports recognition of multiple tack-welded parts.
- Close-range vision refines weld positioning.
- Automatic program generation from welding coordinates and process data.
- Water-cooled torch and automatic cleaning configuration.
TECHNICAL OVERVIEW
Key specifications
| Workstation axes | 6 robot axes + 2 external axes |
|---|---|
| Reference rail length | 12 m |
| Robot reach | 2014 mm |
| Robot payload | 6 kg |
| Robot repeatability | ±0.08 mm |
Configuration reference: HNGJ Global. Workpiece envelope is project-specific. Product image is a configuration illustration. Parameters apply to the referenced configuration. Final scope is confirmed in the technical agreement. Robot-only figures are identified separately.
APPLICATION & PROCESS
Confirm the welding fit.
Shared process guidance for the seven- and eight-axis GMAW workstations.
| Workpiece material | Carbon steel and low-alloy steel; stainless steel requires application validation. |
|---|---|
| Welding method | Gas metal arc welding (GMAW) |
| Reference plate thickness | 5–30 mm |
| Welding positions | PA flat, PB horizontal-vertical fillet, PG vertical-down |
| Shielding gas options | 80% Ar + 20% CO₂; 100% CO₂; 95% Ar + 5% O₂ |
| Solid wire diameter | Ø1.0 / Ø1.2 / Ø1.6 mm |
| Flux-cored wire diameter | Ø1.2 mm |
Gas and wire are selected for the material and qualified welding procedure. Stainless steel suitability requires validation of surface reflection, scanning and arc tracking.
Access matters as much as reach.
Flat-web components must allow camera scanning and torch approach. Reference rib clearances are 150 mm for flat welding and 450 mm for vertical welding, subject to torch geometry and surrounding plate height.
View processes, clearances & jointsSupplemental equipment configuration
| Robot | HLR6-2000D, inverted six-axis robot; 2,000 mm arm radius |
|---|---|
| Control & vision | Welding control software V1.0; air-cooled robot vision and 2048-62 industrial stereo vision for large-format scanning |
| Torch package | 500MR water-cooled torch with automatic cleaning station |
| Welding power source | Dex2 500MPR water-cooled pulsed source with water tank and wire feeder |
| Supplemental rail configuration | 14 m total rail length; carriage and cantilever travel confirmed for the selected layout |
| Operator cabinet | Industrial PC, display, mouse and keyboard |
This is a separate reference configuration from the supplementary sheet. Rail length and robot reach may differ from the catalog configuration above; the final equipment list and working envelope are confirmed in the technical agreement.
A useful brief gets a clearer proposal.
Send material grade and thickness, maximum part dimensions and weight, joint or cutting details, batch size, target output and the installation country. Describe the current process and the bottleneck you want to resolve.
04 / AFTER-SALES SUPPORT
Support throughout operation.
Build a service plan around your equipment, operators and installation location. The following items can be included in the agreed project scope.
Installation & commissioning
Agree checks for the robot installation, external axes where fitted, fixtures, power, gas and extraction. Commissioning reviews coordinate references and sample welds against the agreed process.
Operator training
Training can include job preparation, the supported programming or scanning method, process selection, weld inspection and routine restart procedures.
Care & maintenance
Plan checks for cantilever motion, camera calibration, torch cooling and automatic cleaning. Training can cover part recognition, weld selection, process adjustment and safe restart after a fault.
Troubleshooting & spare parts
Share the equipment model, fault code, operating conditions and relevant photos when requesting support. Diagnosis, replacement parts and any on-site visit are coordinated for the installed configuration and project location.
Warranty & service arrangements
Warranty duration, consumable coverage, software support and response arrangements are confirmed in the project agreement. Overseas on-site work, travel costs and parts delivery are agreed for the destination.
Related equipment
Robotic welding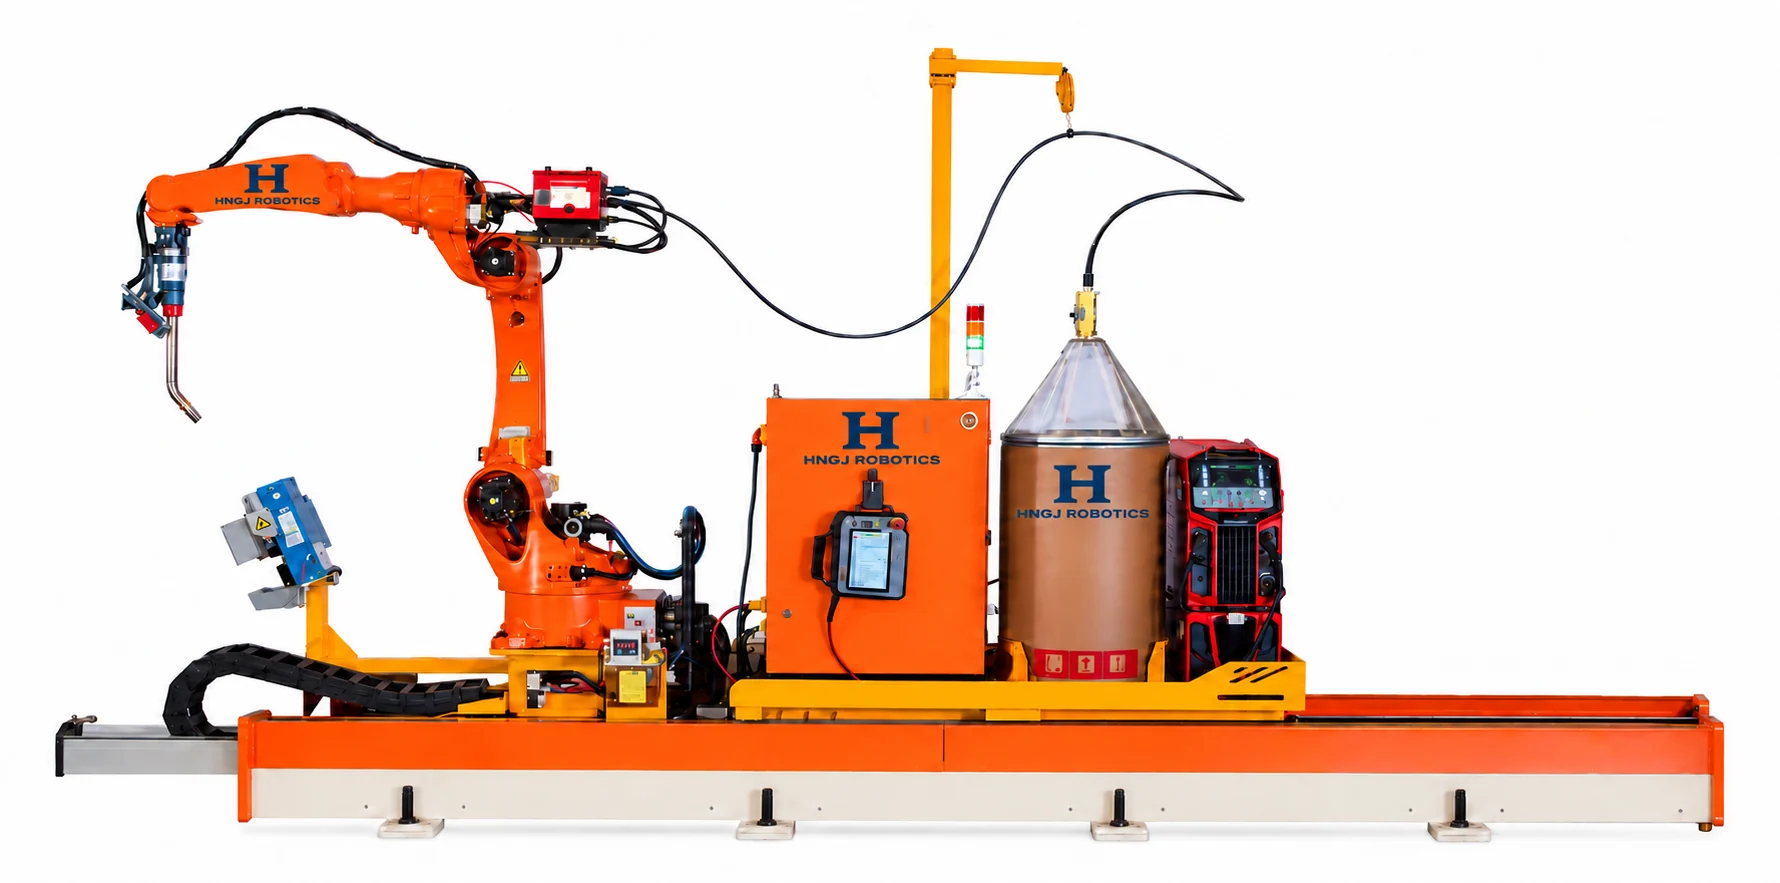
7-axis rail-guided welding
Model-driven or scan-driven welding for open steel structures.
Robotic welding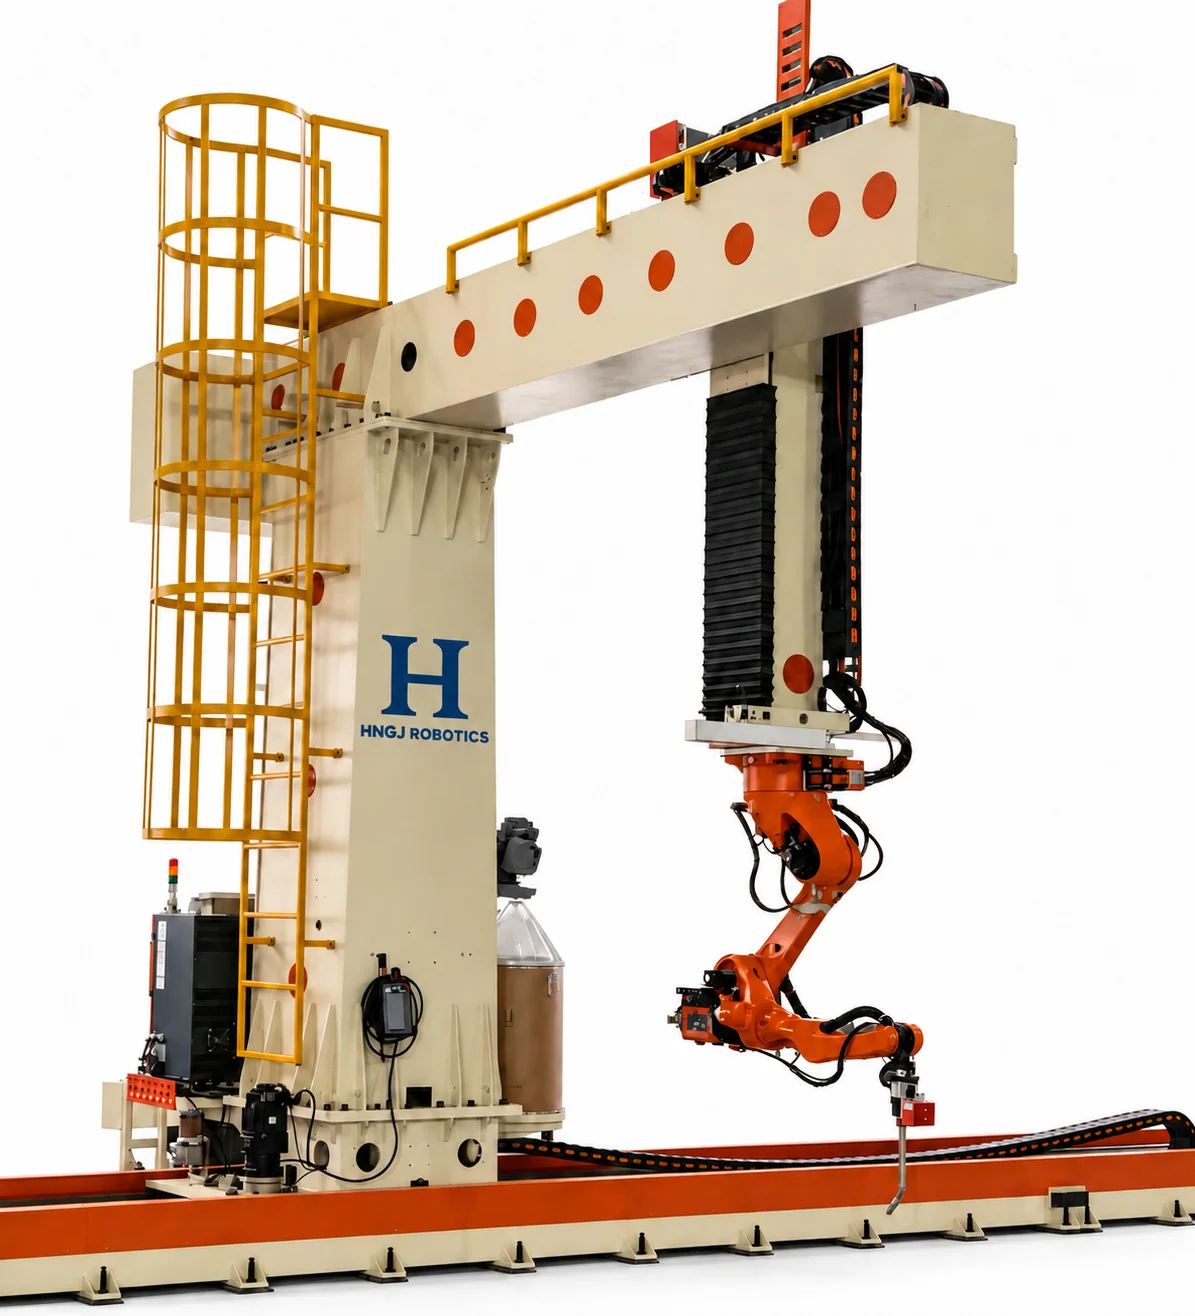
9-axis cantilever welding
Reach further with three external motion axes for larger components.
Robotic welding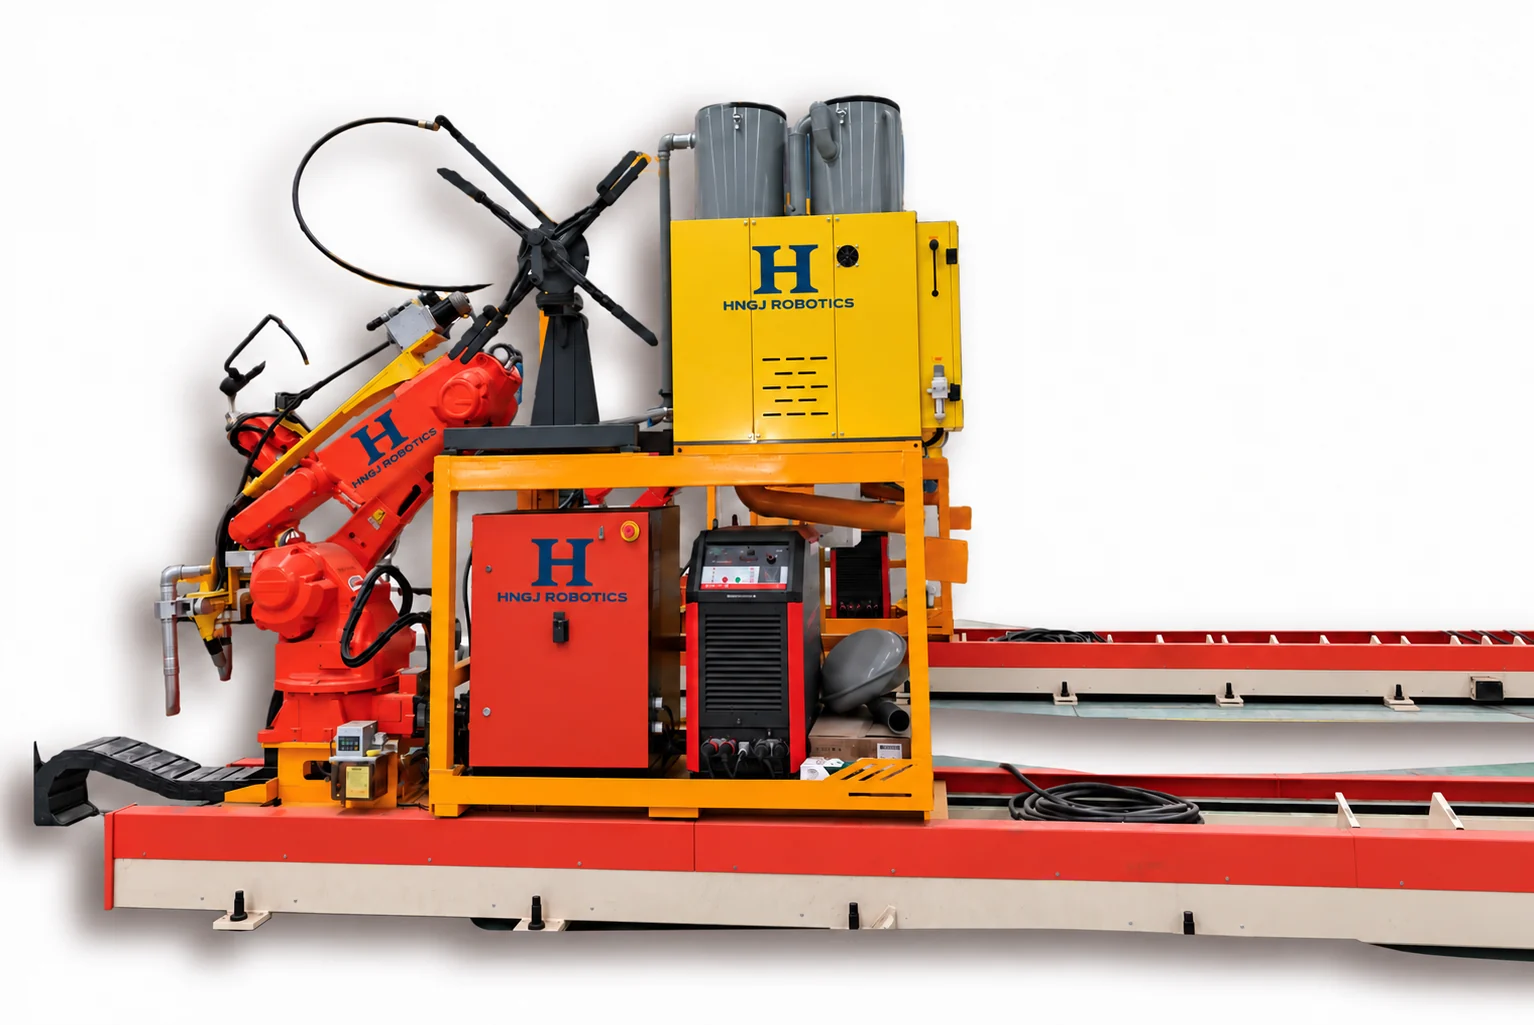
7-axis submerged arc welding
Groove scanning and multipass welding for thick structural steel.
Your next step starts with a conversation.
Tell us what you make. Let’s define the right equipment configuration.