Main seams in fabricated H-section columns.
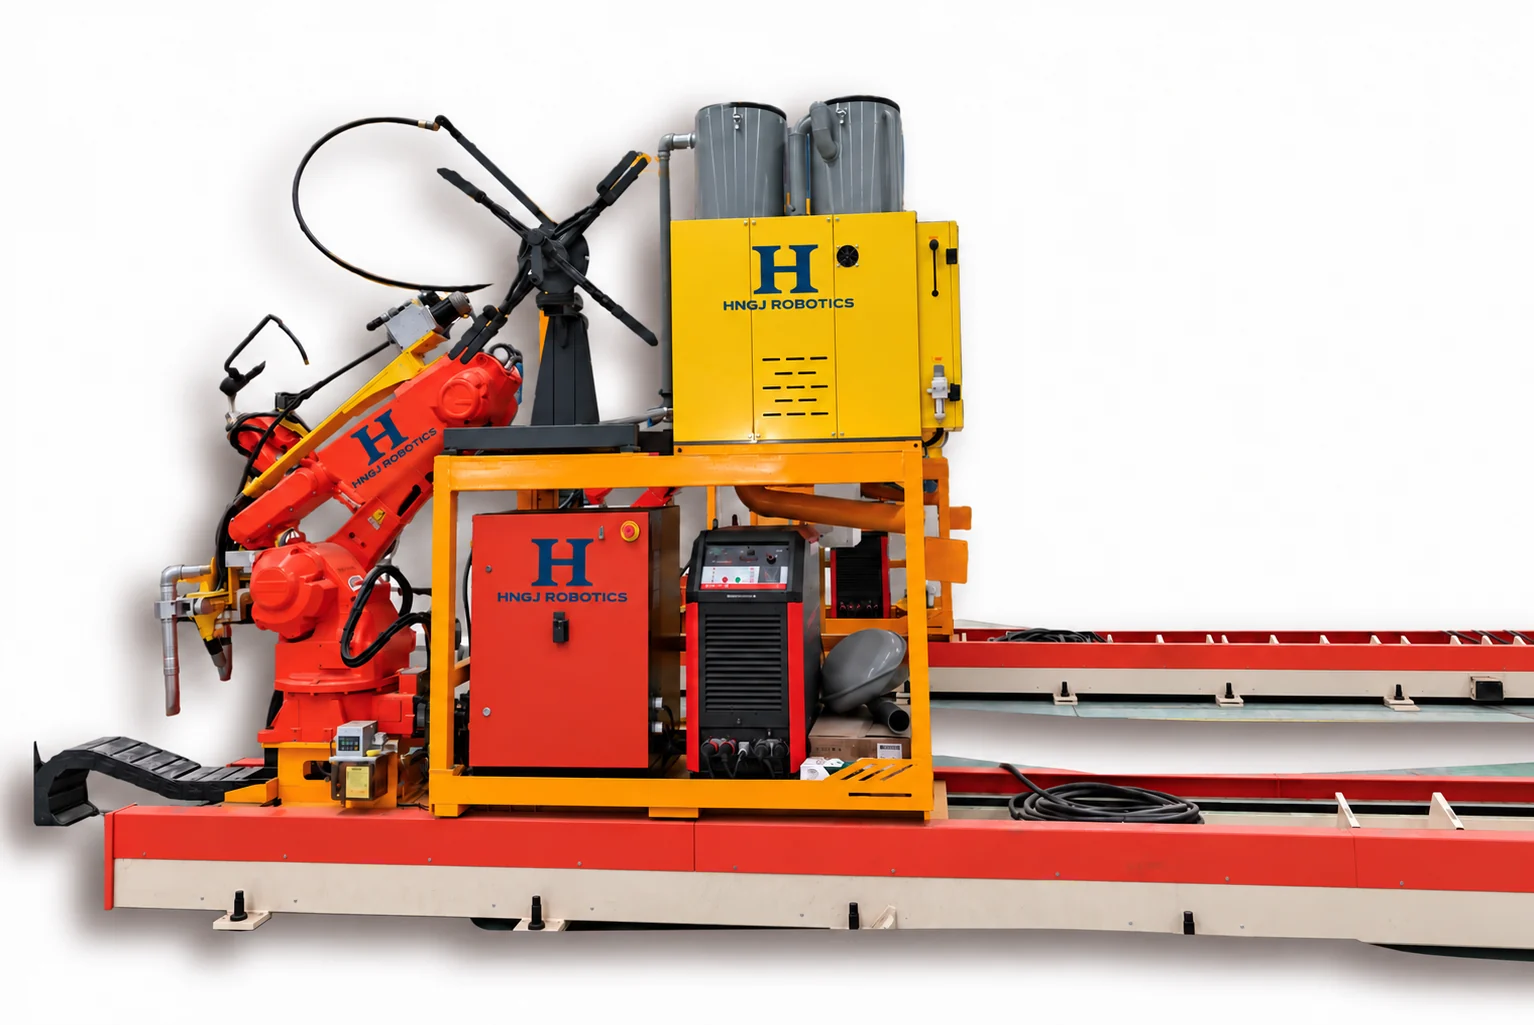
7-AXIS · SAW
7-axis submerged arc welding
For full- and partial-penetration main welds in H-section, box and cruciform columns. Laser groove scanning supports adaptive multilayer and multipass welding.
Robotic welding16–80 mm plate thickness
Enquire about this equipment01 / PRODUCT OVERVIEW
How this equipment works.
A rail-guided robotic submerged arc welding system for main seams in thick structural-steel components. The reference process range covers 16–80 mm plate and full- or partial-penetration joints in suitable H-section, box and cruciform columns.
Laser scanning measures the groove to support adaptive multilayer, multipass welding. The sequence covers root, filling and capping passes, with digital current, voltage and travel-speed settings and a flux feed/recovery system. Operators set up the joint and confirm scanning results before automatic operation.
Find the fit for your parts.
Accessible longitudinal joints in box columns.
Cruciform-column joints and similar thick-plate seams following process review.
Before choosing a configuration
Provide groove drawings, root gap, plate thickness, weld length and penetration requirements. Joint position, flux containment and torch access must suit the submerged arc process.
03 / PROCESS & CONFIGURATION
Designed for the task.
- Laser groove scanning and seam tracking.
- Root, filling and capping pass workflows.
- Digital current, voltage and travel-speed settings.
- Automatic flux feeding and recovery configuration.
TECHNICAL OVERVIEW
Key specifications
| Plate thickness | 16–80 mm |
|---|---|
| Reference rail length | 12 m |
| Reference weld length | 8 m |
| Power source | Megmeet SA-1250 |
| Power-source current range | 100–1250 A |
Configuration reference: HNGJ Global. Automatic operation includes operator setup and scan confirmation. Parameters apply to the referenced configuration. Final scope is confirmed in the technical agreement. Robot-only figures are identified separately.
A useful brief gets a clearer proposal.
Send material grade and thickness, maximum part dimensions and weight, joint or cutting details, batch size, target output and the installation country. Describe the current process and the bottleneck you want to resolve.
04 / AFTER-SALES SUPPORT
Support throughout operation.
Build a service plan around your equipment, operators and installation location. The following items can be included in the agreed project scope.
Installation & commissioning
Agree checks for the robot installation, external axes where fitted, fixtures, power, gas and extraction. Commissioning reviews coordinate references and sample welds against the agreed process.
Operator training
Training can include job preparation, the supported programming or scanning method, process selection, weld inspection and routine restart procedures.
Care & maintenance
Support planning covers groove-sensor calibration, wire-feed inspection, power-source checks and flux-feed/recovery cleaning. Training should address pass setup, parameter records and interruption recovery.
Troubleshooting & spare parts
Share the equipment model, fault code, operating conditions and relevant photos when requesting support. Diagnosis, replacement parts and any on-site visit are coordinated for the installed configuration and project location.
Warranty & service arrangements
Warranty duration, consumable coverage, software support and response arrangements are confirmed in the project agreement. Overseas on-site work, travel costs and parts delivery are agreed for the destination.
Related equipment
Robotic welding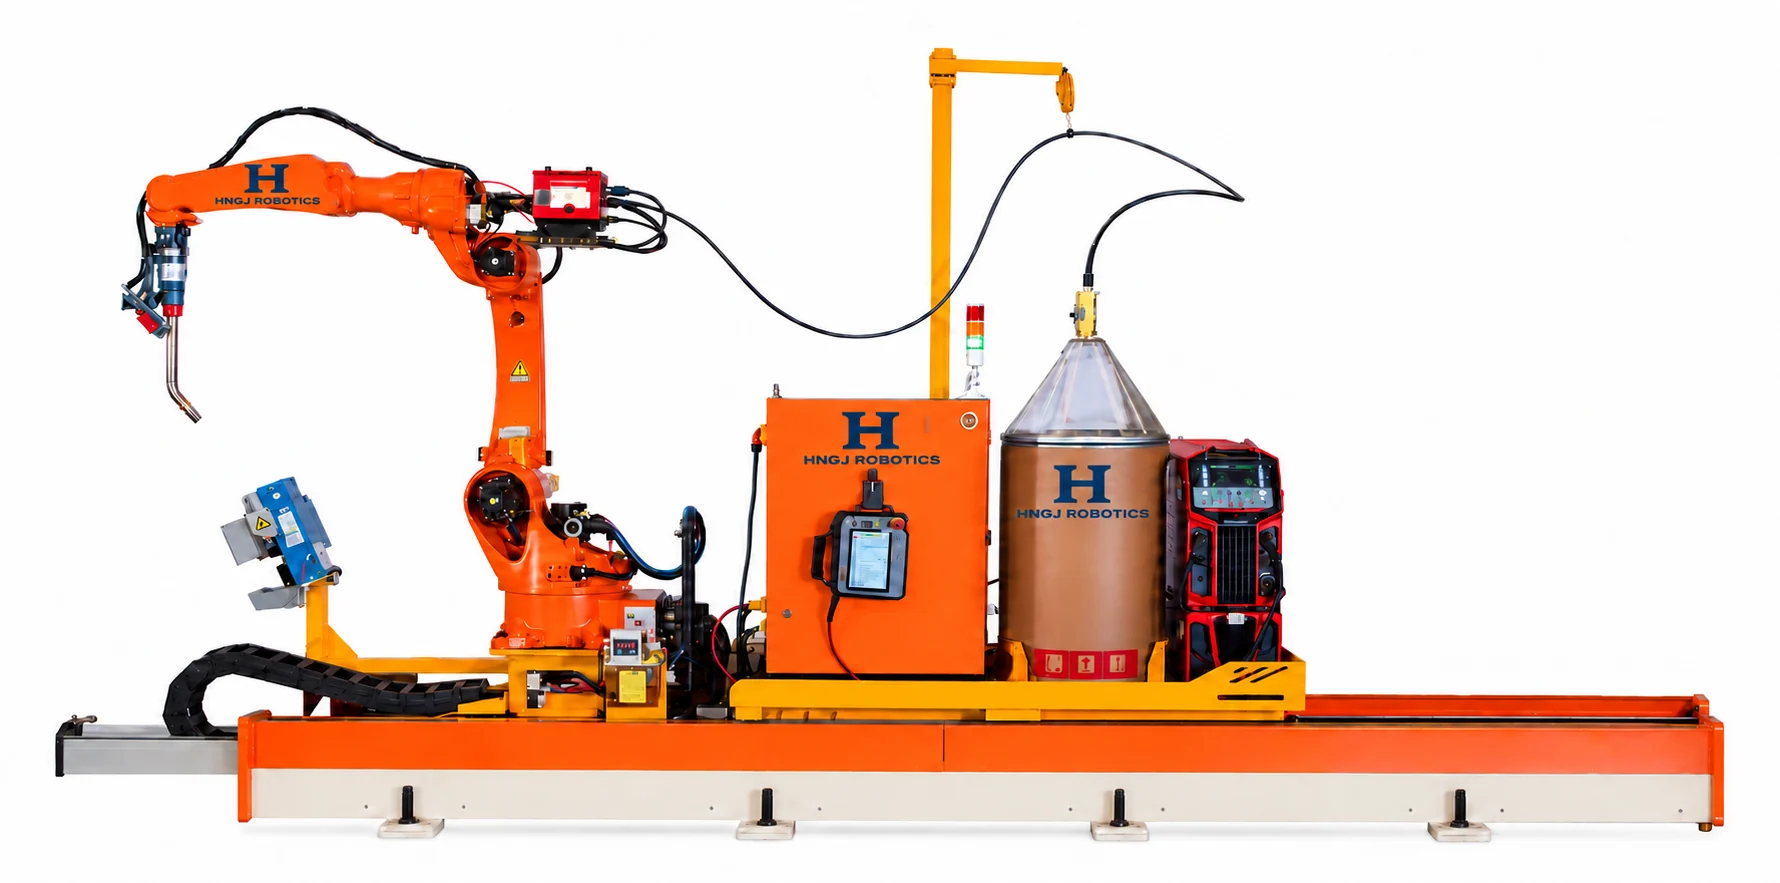
7-axis rail-guided welding
Model-driven or scan-driven welding for open steel structures.
Robotic welding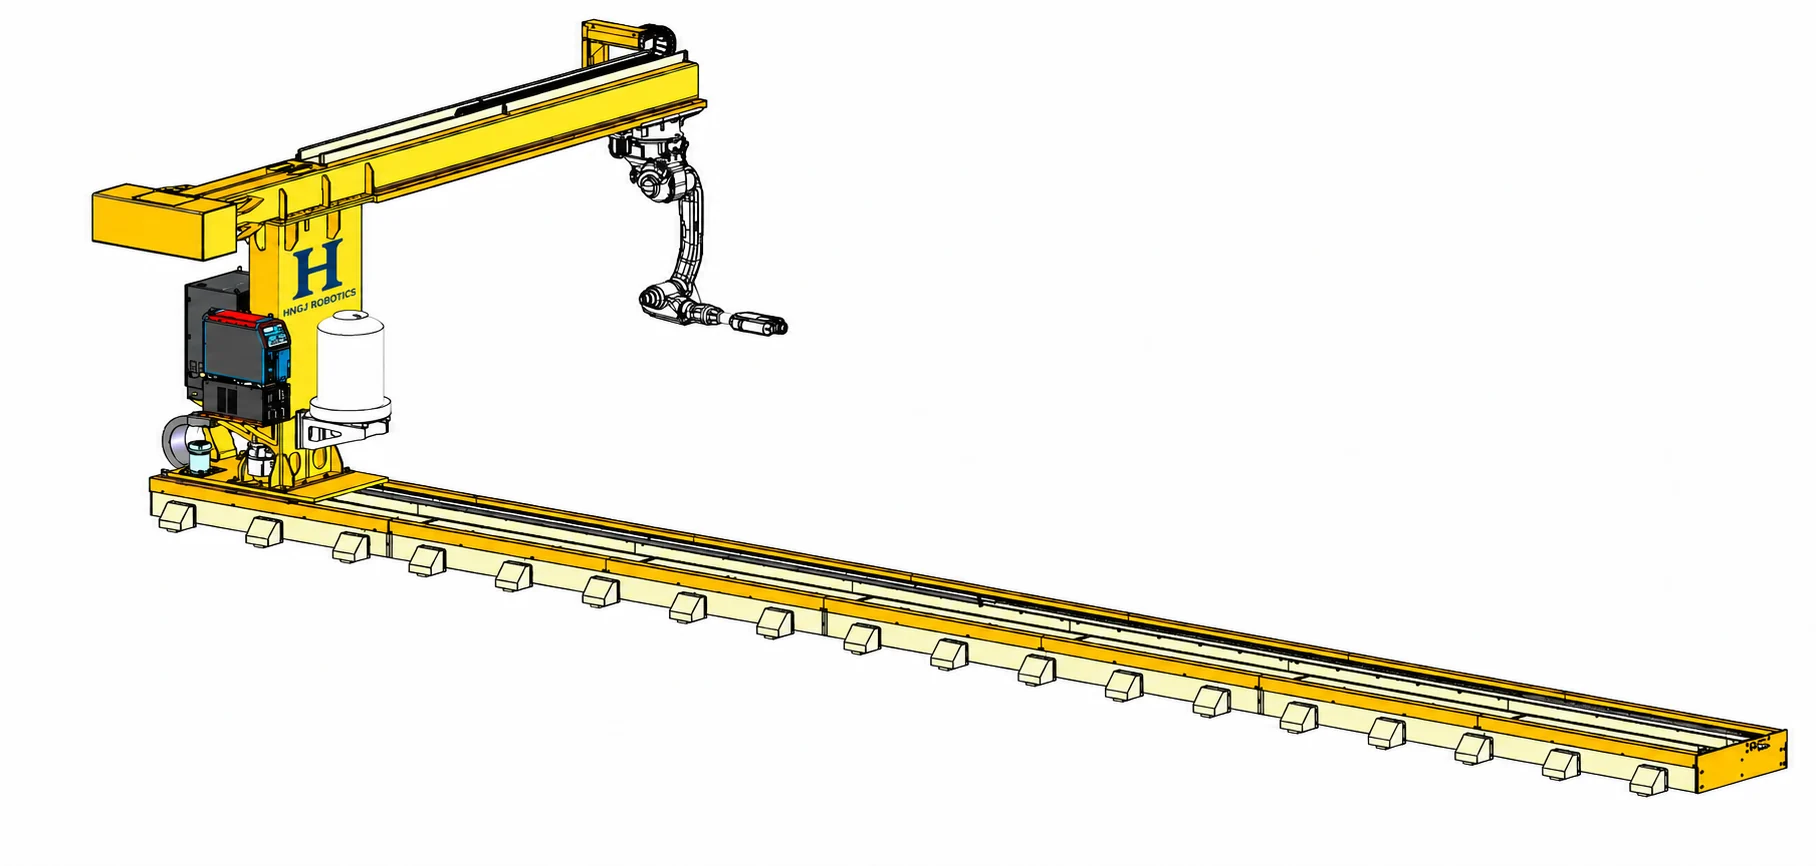
8-axis cantilever welding
A suspended robot and two travel axes for flexible cell layouts.
Robotic welding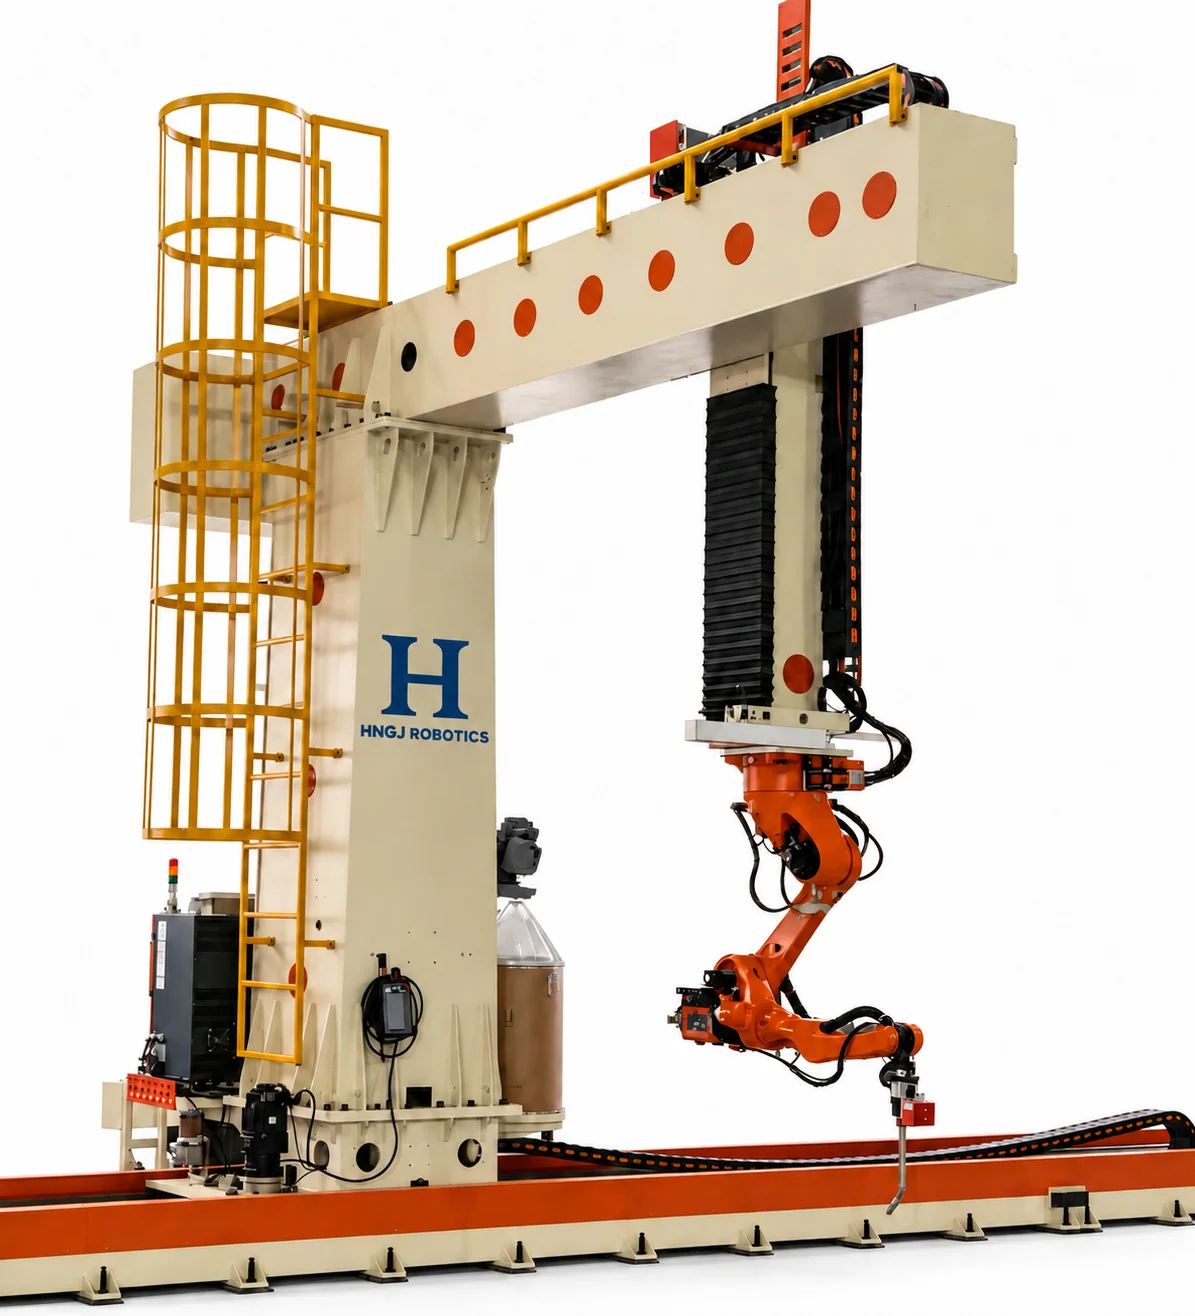
9-axis cantilever welding
Reach further with three external motion axes for larger components.
Your next step starts with a conversation.
Tell us what you make. Let’s define the right equipment configuration.